OmniHand
Pro
2025
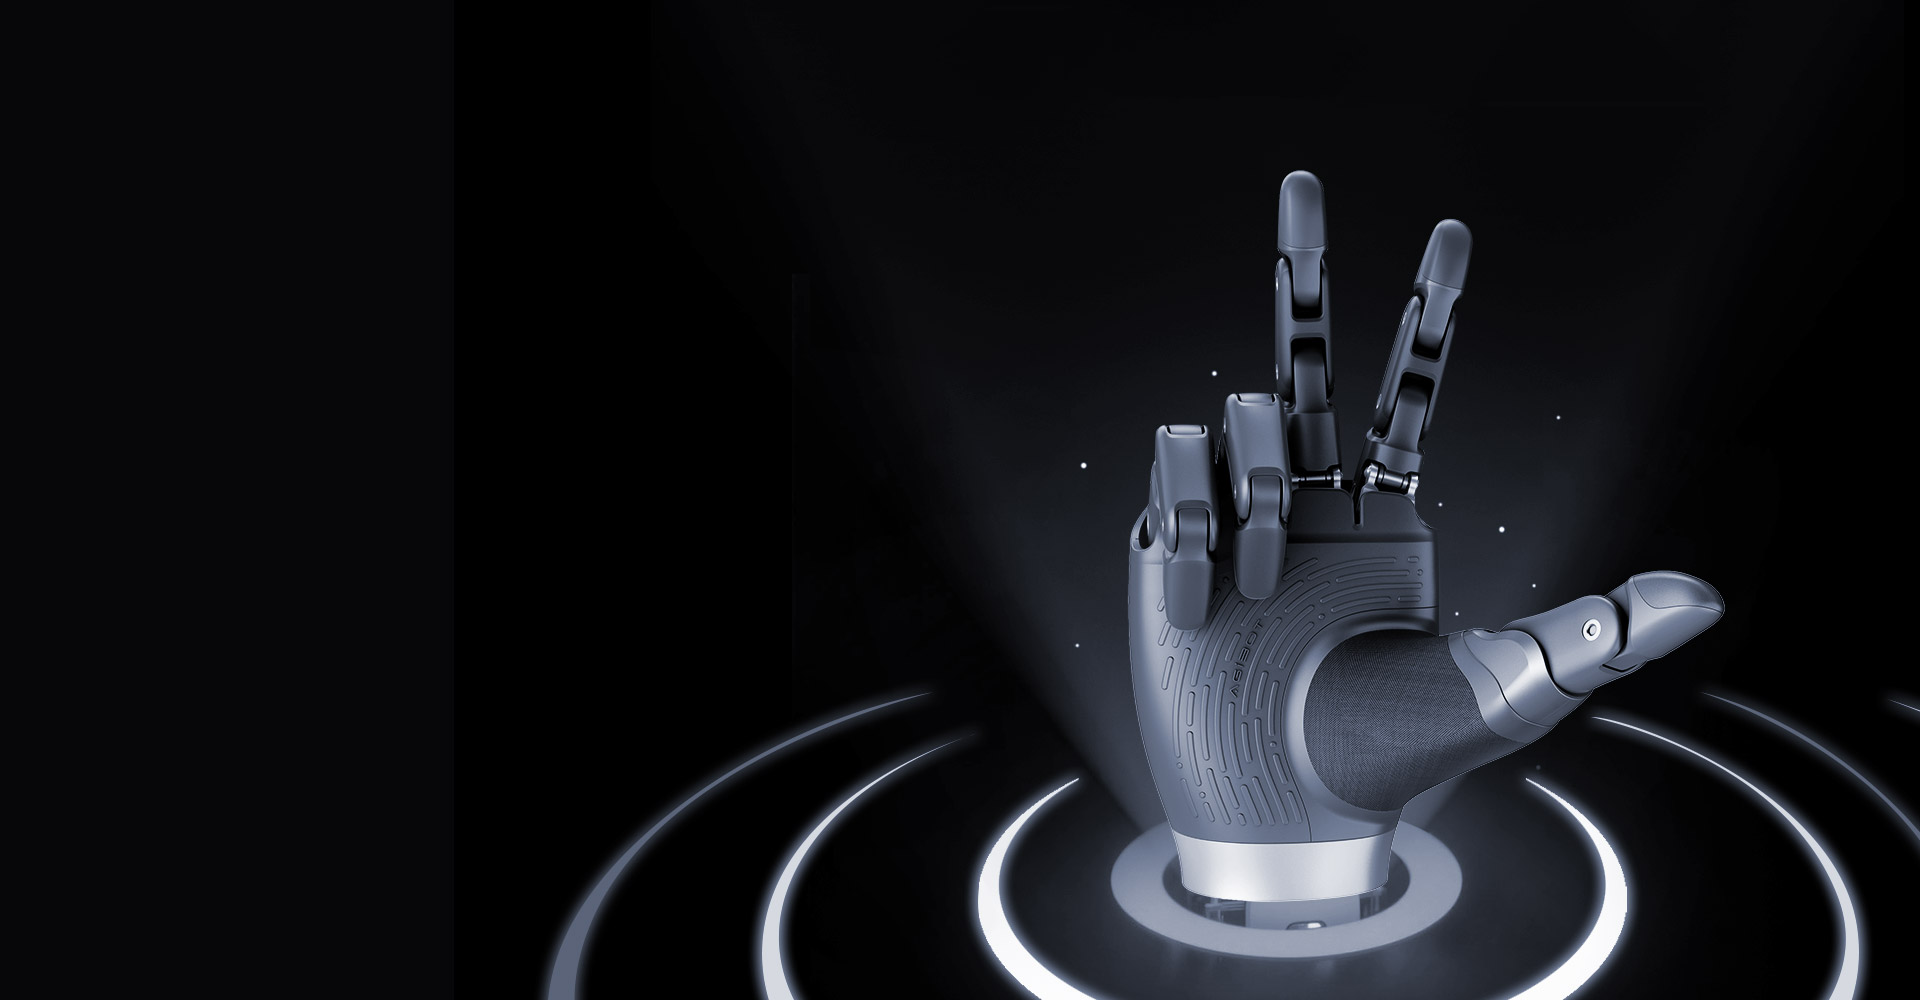
High-Integration Multi-Functional Dexterous Hand
Enhanced Perception, More Capabilities
Human-like Size | All-around Operation | Superior Perception

Human-sized
19 degrees of freedom, weighing only 750g
Smaller, lighter, and more human-like among dexterous hands with the same configuration

All-round Operation
Optimized structural design
Effortless handling of professional tools
Maximum fingertip force of 20N with one hand

High-Sensitivity Perception
Multi-modal sensing (position, normal force, tangential force, proximity)
Achieves up to 0.01N-level sensitivity with intelligent algorithms
Package Contents
-
 OmniHand ×1
-
 CANFD Communication Cable ×1
-
 Power Cable ×1
-
 Certificate of Conformity ×1
Product Parameters

| Category | Parameter | |
Main Unit Specifications | Model | OmniHand Pro 2025 |
Weigh | ≤750g | |
Size | 207 × 98 × 56 mm | |
Material | PA + Silicone | |
Active DOF | 12 | |
Total DOF | 19 | |
Transmission | Linkage transmission | |
Drive Method | Motor + Screw Rod | |
Number of Joints | 19 | |
Joint Range | Four fingers flexion: 80°; Four fingers abduction/adduction: ±10°; Thumb flexion: 50°; Thumb abduction/adduction: 90°; Thumb rotation: 50° | |
Minimum closing time (typ.) | 0.8s | |
Minimum grasp diameter | 2mm | |
Finger reposition accuracy (typ.) | 0.02mm | |
Max fingertip force (typ.) | 20N | |
Operating voltage | 12~24V | |
Idle current | 0.5A | |
Max current | 4.5A | |
Communication interface | CANFD | |
Operating temperature | -20~50℃ | |
Load capacity (palm up, 5 cm rigid object) | 35kg | |
Load capacity (palm down, 5 cm rigid object) | 5kg | |
Perception Specifications | Sensor array configuration | Fingertip 3-axis force; Palm 1-axis force; 150+ tactile points |
Resolution | 0.01N | |
Sensing range | 0~50N | |
Max permissible force (non-destructive) | 1000N | |
Software Funcations | OS compatibility | Windows |
Communication rate | 1kHz | |
Data packet size | 48 bytes | |
Sensory feedback | Joint position, joint speed, joint torque, joint temperature, electrical current, tactile pressure info | |
Control modes | Speed mode, Position mode, Force mode, Hybrid position-force mode, Tactile mode | |
Secondary development | Supported | |
| Others | Compatibility | Compatible with others |
